AI Poland 2026 · Speaker
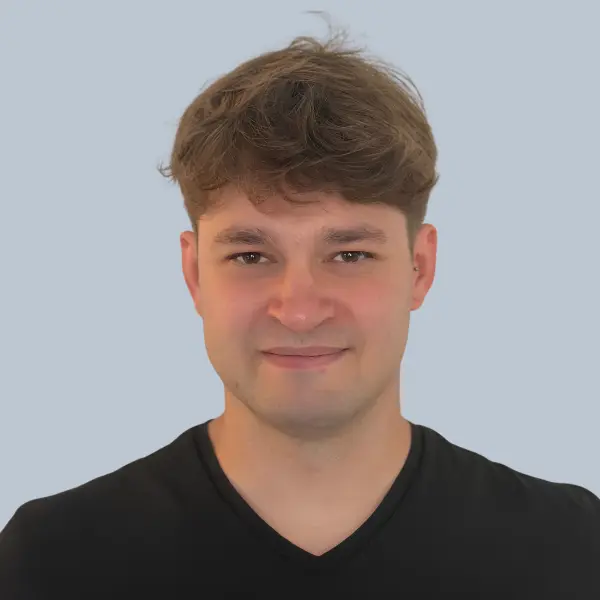
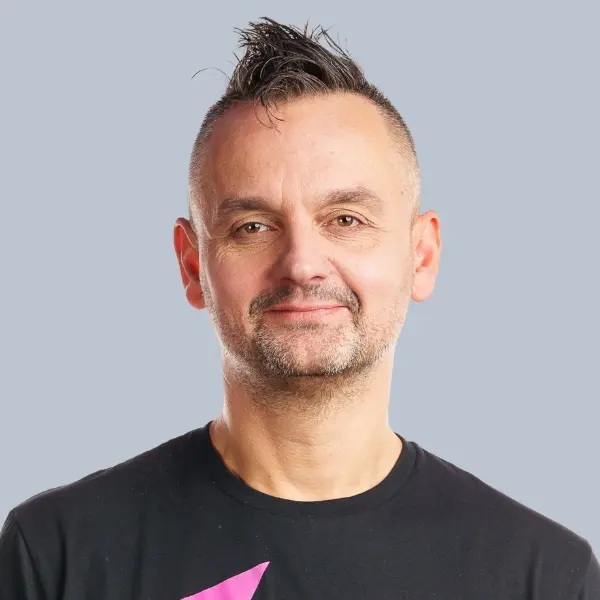
Adrian Romanski
GDE, PSPA member, Software Engineer, Push-Based | Poland
Talk
Keynote: The World Is Your Next Runtime
Talk at AI Poland
Thursday, Nov 19, 2026 · 10:20 - 10:30
Where
Onsite at Multikino Złote Tarasy, Warsaw
· or join online
AI agents are learning to act across our apps, but what happens when we give them access to the physical world? Suddenly, the environment has no API documentation, actions can’t always be undone, and a small error can send your 80kg+ superhuman robot through the wall. In this keynote, we’ll explore Physical AI through a software developer’s lens: how robots learn in simulation, how vision-language-action models connect instructions to movement, and what it takes to make those capabilities work on real hardware.
About Adrian Romanski
My programming journey began with C++ in high school.
I enjoyed it so much that I decided to study at PJATK, where I specialized in robotics. However, after gaining my first professional experience, I realized that this wasn’t quite the right path for me. I decided to shift my focus to web development, starting out as a Java developer working with the Spring framework.
At first, frontend development didn’t really appeal to me - until someone at work introduced me to Angular. It was love at first sight! Since then, I’ve been growing as a full-stack developer.
I specialize in Component Driven Architecture using Storybook, application optimization, and monorepo architecture based on Nx. Over the last years, my main focus has become accessibility (A11Y), which has captivated me just as much as Angular did at the start of my journey.
Outside of work, I spent over 15 years hardcore raiding in World of Warcraft.
I’m also a big anime fan and a passionate squash player.
I enjoyed it so much that I decided to study at PJATK, where I specialized in robotics. However, after gaining my first professional experience, I realized that this wasn’t quite the right path for me. I decided to shift my focus to web development, starting out as a Java developer working with the Spring framework.
At first, frontend development didn’t really appeal to me - until someone at work introduced me to Angular. It was love at first sight! Since then, I’ve been growing as a full-stack developer.
I specialize in Component Driven Architecture using Storybook, application optimization, and monorepo architecture based on Nx. Over the last years, my main focus has become accessibility (A11Y), which has captivated me just as much as Angular did at the start of my journey.
Outside of work, I spent over 15 years hardcore raiding in World of Warcraft.
I’m also a big anime fan and a passionate squash player.
Learn from the Best Speakers 2026
Companies that support our community
Our Sponsors 2026
By becoming a sponsor of AI Poland, you gain a unique opportunity to showcase your company and products to hundreds of forward-thinking developers, engineers, and AI practitioners from across Europe.
This kind of exposure can drive meaningful interest in your solutions, help you connect with new business partners, and attract top tech talent.
To learn more about our sponsorship opportunities, please fill in the form.
Gold Sponsor
Gold Sponsor
Silver Sponsor
Silver Sponsor
Special Sponsor
Special Sponsor
Special Sponsor
Special Sponsor
Special Sponsor
ngGirls Sponsor
Stay in the loop Join our mailing list
Sign up to receive updates about AI Poland, including workshops, speaker announcements, ticket releases, AI Awards, expert interviews, CFP details, and other exclusive content. We won’t spam you — only thoughtfully curated updates we believe you’ll find truly valuable. You can unsubscribe at any time. More information available here.
- No spam
- Unsubscribe anytime
- Only the good stuff